Benewake NOVA20 LiDAR Targets Robot Blind Spots
Benewake's NOVA20 is a 20-channel near-field LiDAR for robots. Its stated one meter reach leaves much of the safety case to the integrator.
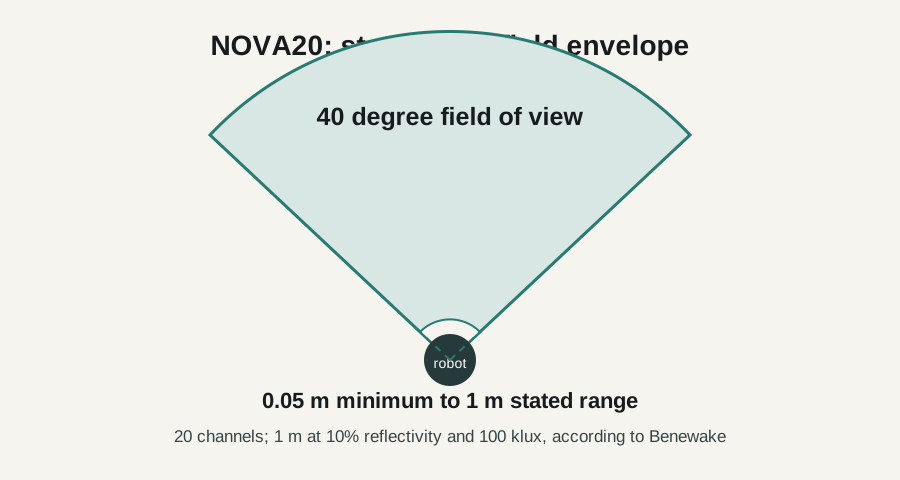
Benewake NOVA20 LiDAR launched on October 12 as a solid-state sensor intended to cover close-in blind spots on mobile robots, humanoids and quadrupeds. The company states a 0.05 to 1 meter detection span, with 20 channels across a 40 degree field of view.[1]
The pitch is narrow by design. This is not a replacement for navigation LiDAR or cameras. Benewake positions it as an extra distance-sensing layer near a chassis, wrist, ankle or robot corner, where a larger sensor can miss a low obstacle or drop-off.[1]
What does Benewake NOVA20 LiDAR measure?
Benewake NOVA20 LiDAR measures direct distance in a stated near-field zone. It does not produce a camera image. Benewake lists 20 detection channels, a 40 degree field of view, a 10 Hz frame rate, and ranging accuracy of 3 cm or less at one standard deviation.[3]
Benewake says the sensor can detect at 1 meter on a 10 percent reflectivity target under 100 klux ambient light. It also lists average power below 1 W, mass below 5 g, UART, and support for ROS, Linux and Windows.[3] Those are manufacturer specifications, not an independent performance test.
"Specific mounting positions, detection performance, and control strategies should be validated against each robot's structure and actual operating environment."[3]
Where would a robot use it?
Benewake names chassis corners for mobile robots, plus wrists and ankles for humanoids. Its stated applications include edge following, drop-off detection and proximity sensing before contact.[1] The product page also calls out outdoor robots and unmanned vehicles for blind-spot and drop-off work.[2]
The geometry matters. A 40 degree field does not create full-body coverage from one unit. An integrator would need to choose locations, account for occlusion by limbs or payloads, and test the resulting coverage while the robot moves. Benewake's own technical note says mounting and control need validation on the actual robot.[3]
For system-level context, our legged robot safety standards guide separates a component claim from the evaluation of a completed machine. Teams designing a mobile manipulator can also compare the controller side in our report on the FANUC R-50iA Compact DC Controller.
What NOVA20 does not establish
NOVA20 is a sensing component, not a published safety case. Benewake describes a 905 nm VCSEL as Class 1 and calls the sensor eye-safe.[3] That statement concerns the light source. It does not show that a robot will stop in time, see every obstacle, or meet the requirements of a particular site.
The company has not published a price, ingress-protection rating, stopping-distance result or independent trial result for a completed robot in the materials reviewed for this report.[1][2][4]
Buyers and integrators should request the datasheet. They should define the smallest hazard and response time that matter, then test the sensor with the intended mounting, covers, surface materials, light and robot motion.
Benewake NOVA20 LiDAR FAQ
Frequently asked questions
What is the stated range of Benewake NOVA20 LiDAR?
Benewake states a detection span from 0.05 meter to 1 meter. Its 1 meter claim specifies a 10 percent reflectivity target under 100 klux ambient light.
Does NOVA20 replace a robot safety assessment?
No. Benewake publishes component specifications and advises validation on the actual robot. Those specifications do not establish the performance or safety of a complete robot application.
What interface does NOVA20 use?
Benewake lists UART and support for ROS, Linux and Windows.
Sources
- https://www.prnewswire.com/news-releases/benewake-introduces-nova20-lidar-to-close-the-near-field-gap-in-robot-safety-perception-302905677.html
- https://en.benewake.com/NOVA20/index.html
- https://en.benewake.com/NewsUpdates/info_itemid_6183.html
- https://en.benewake.com/DataDownload/index_pid_20_lcid_2105.html